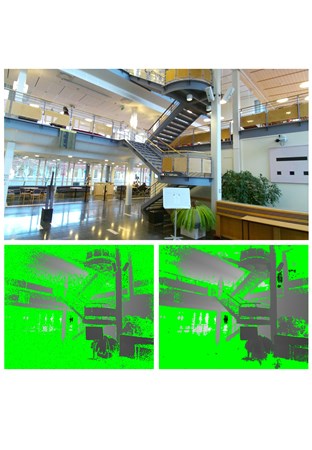
Carl Hoffstedt, Per-Erik Forssén, Anton Wiberg,  Semantic annotation of 3D point clouds via label transfer from BIM models for AEC applications, Results in Engineering (RINENG) 30:110796 (2026)
 https://doi.org/10.1016/j.rineng.2026.110796
Johannes Hägerlind, Bao-Long Tran, Urs Nathanael Waldmann, Per-Erik Forssén, Robust Multi-view Self-Calibration from Dense Matches, Proceedings of the 21st International Conference on Computer Vision Theory and Applications, Antonino Furnari, Petia Radeva (eds.), VISIGRAPP, pp. 307-318, Setúbal, Portugal (2026) https://doi.org/10.5220/0014253000004084  https://arxiv.org/pdf/2512.15608
Pavlo Melnyk, Cuong Le, Urs Waldmann, Per-Erik Forssén, Bastian Wandt, On the Role of Rotation Equivariance in Monocular 2D-to-3D Human Pose Lifting (2026) https://arxiv.org/abs/2601.13913
Shipeng Liu, Garima Bazard, Khac-Hoang Ngo, Per-Erik Forssén, Point Cloud Transmission With Patch-Based Rate Adaptation (2026) https://arxiv.org/abs/2610.29479
Johannes Hägerlind, Bao-Long Tran, Urs Waldmann, Per-Erik Forssén, Robust Multi-view Camera Calibration from Dense Matches (2025) https://arxiv.org/abs/2512.15608